Overview
Substation (gardu induk) equipment is inspected on fixed rounds: the same disconnectors, busbar joints, bushings and cable terminations, every shift. HotDog walks such a round on its own on a Deep Robotics Lynx M20, stops in front of each piece of equipment, points the pod at it and checks it for overheating and partial discharge.
HotDog runs on Dharma, the shared autonomy stack, with the M20's own odometry instead of a LiDAR-inertial estimator and without maps: routes are taught and repeated from the dock.
The robot
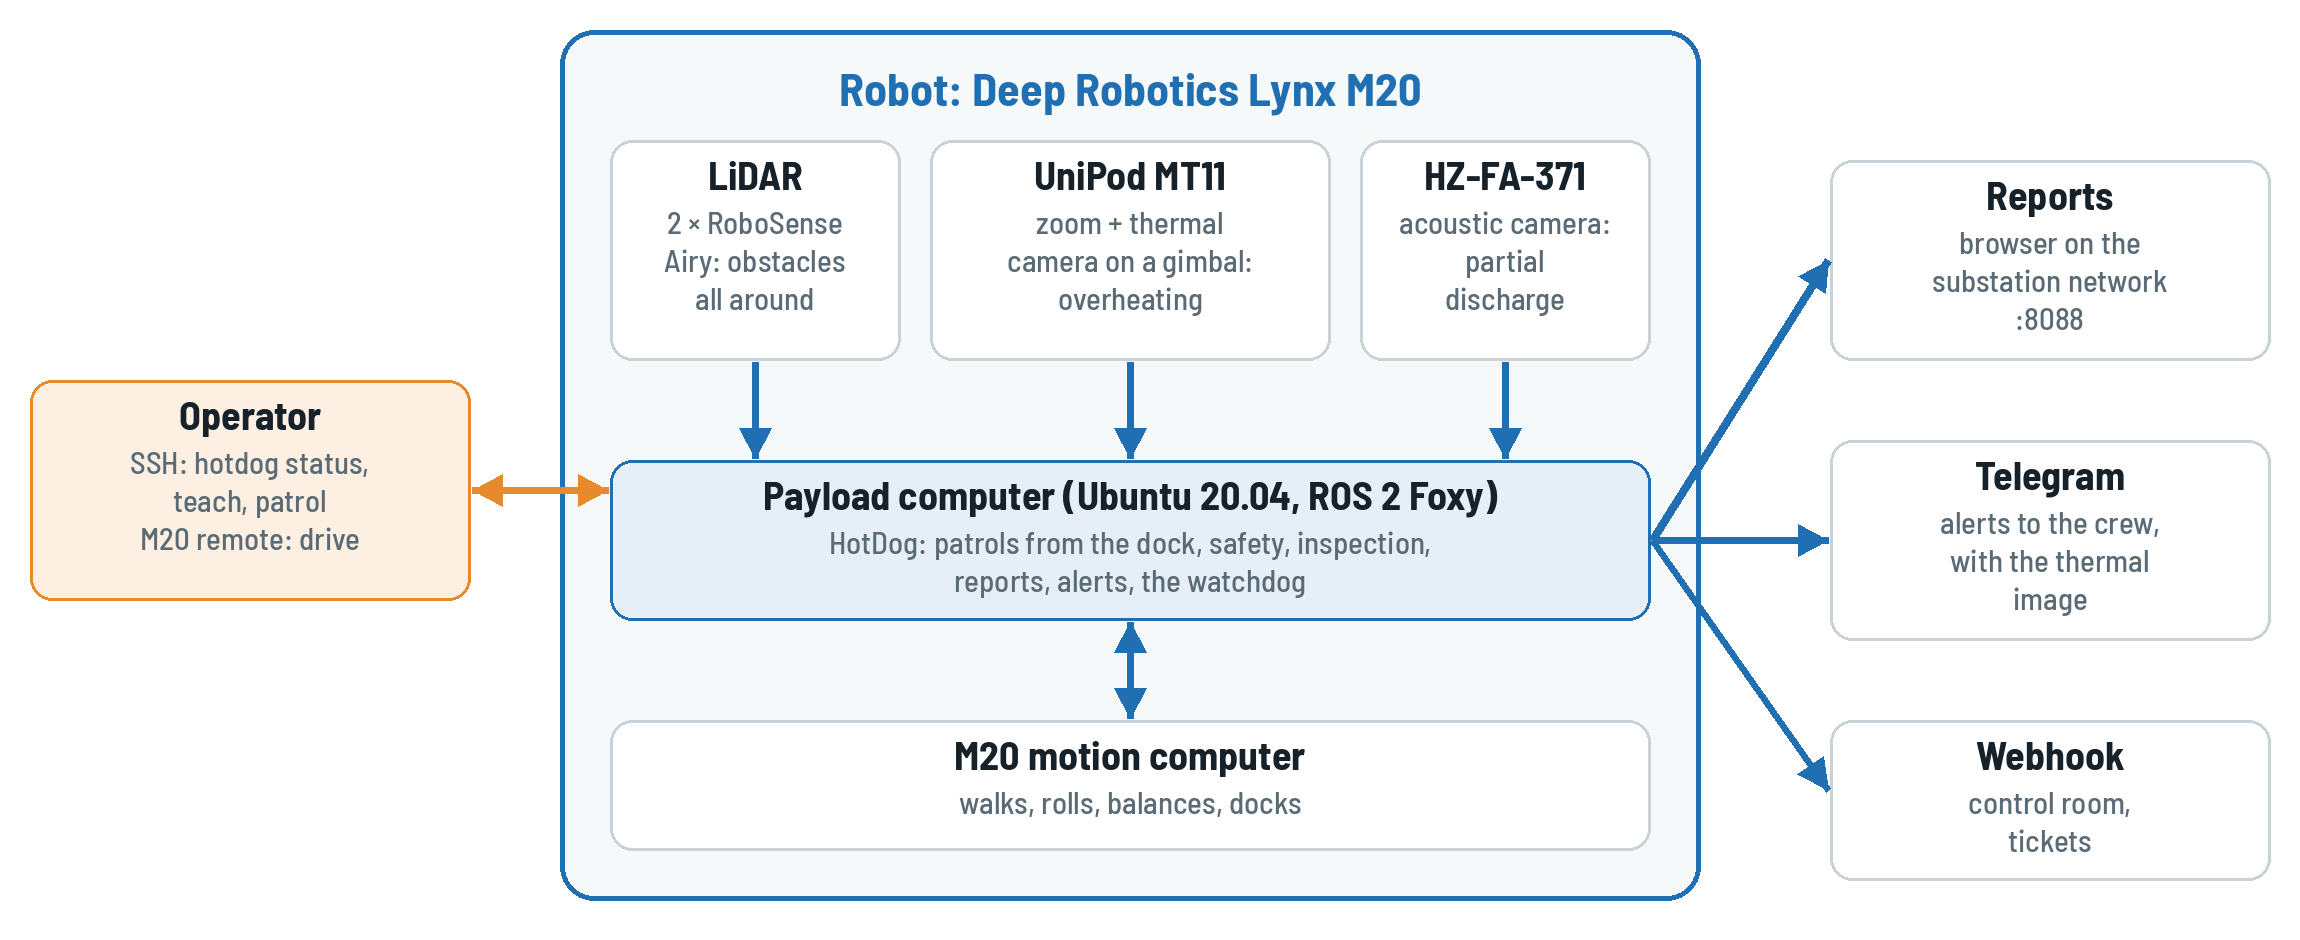
| Component | Model | Role |
|---|---|---|
| Robot base | Deep Robotics Lynx M20 (wheel-legged) | odometry, IMU, battery, motion (UDP protocol V1.3.0) |
| LiDAR | 2 × RoboSense Airy (front, rear), 96 beams | obstacle sectors, the 360° protective field |
| Pod | Reebot UniPod MT11 (zoom + thermal, gimbal) | overheat analysis, evidence images |
| Acoustic | Hertzinno HZ-FA-371 acoustic camera | partial discharge (corona, surface, floating) |
| Compute | payload computer, Ubuntu 20.04 + ROS 2 Foxy | the whole stack |
Teach once, then patrol
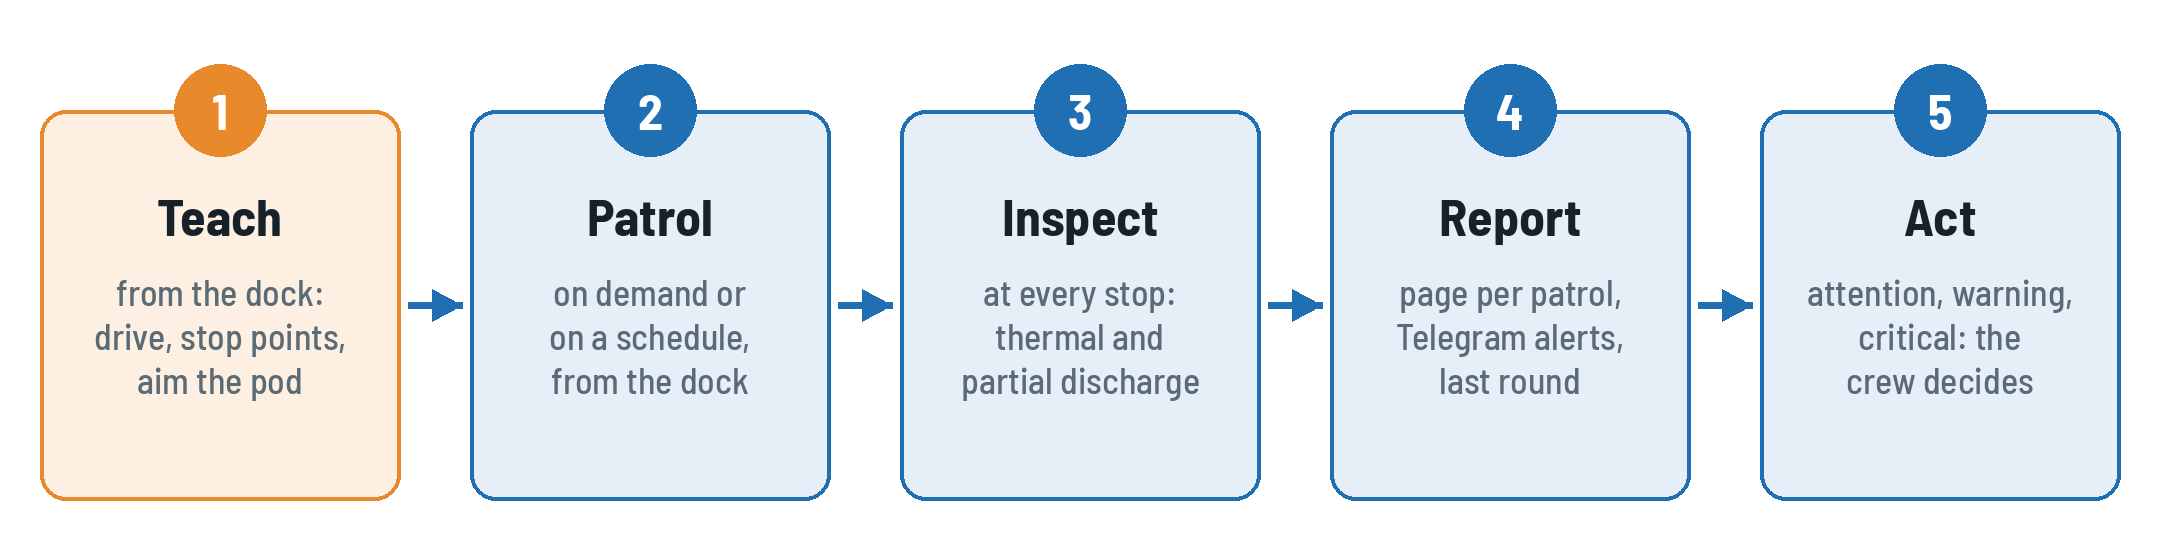
- Teach a route once: drive it with the M20 remote from the dock, mark a stop point at each piece of equipment and aim the pod at it (
hotdog teach,hotdog aim). - Patrol on demand (
hotdog patrol) or at fixed times: HotDog re-anchors at the dock, walks the route, inspects at every stop point and docks again to charge. - Read the report at
http://<robot>:8088/and act on the findings: attention, warning, critical. Warning and critical findings reach the crew's Telegram group at once.
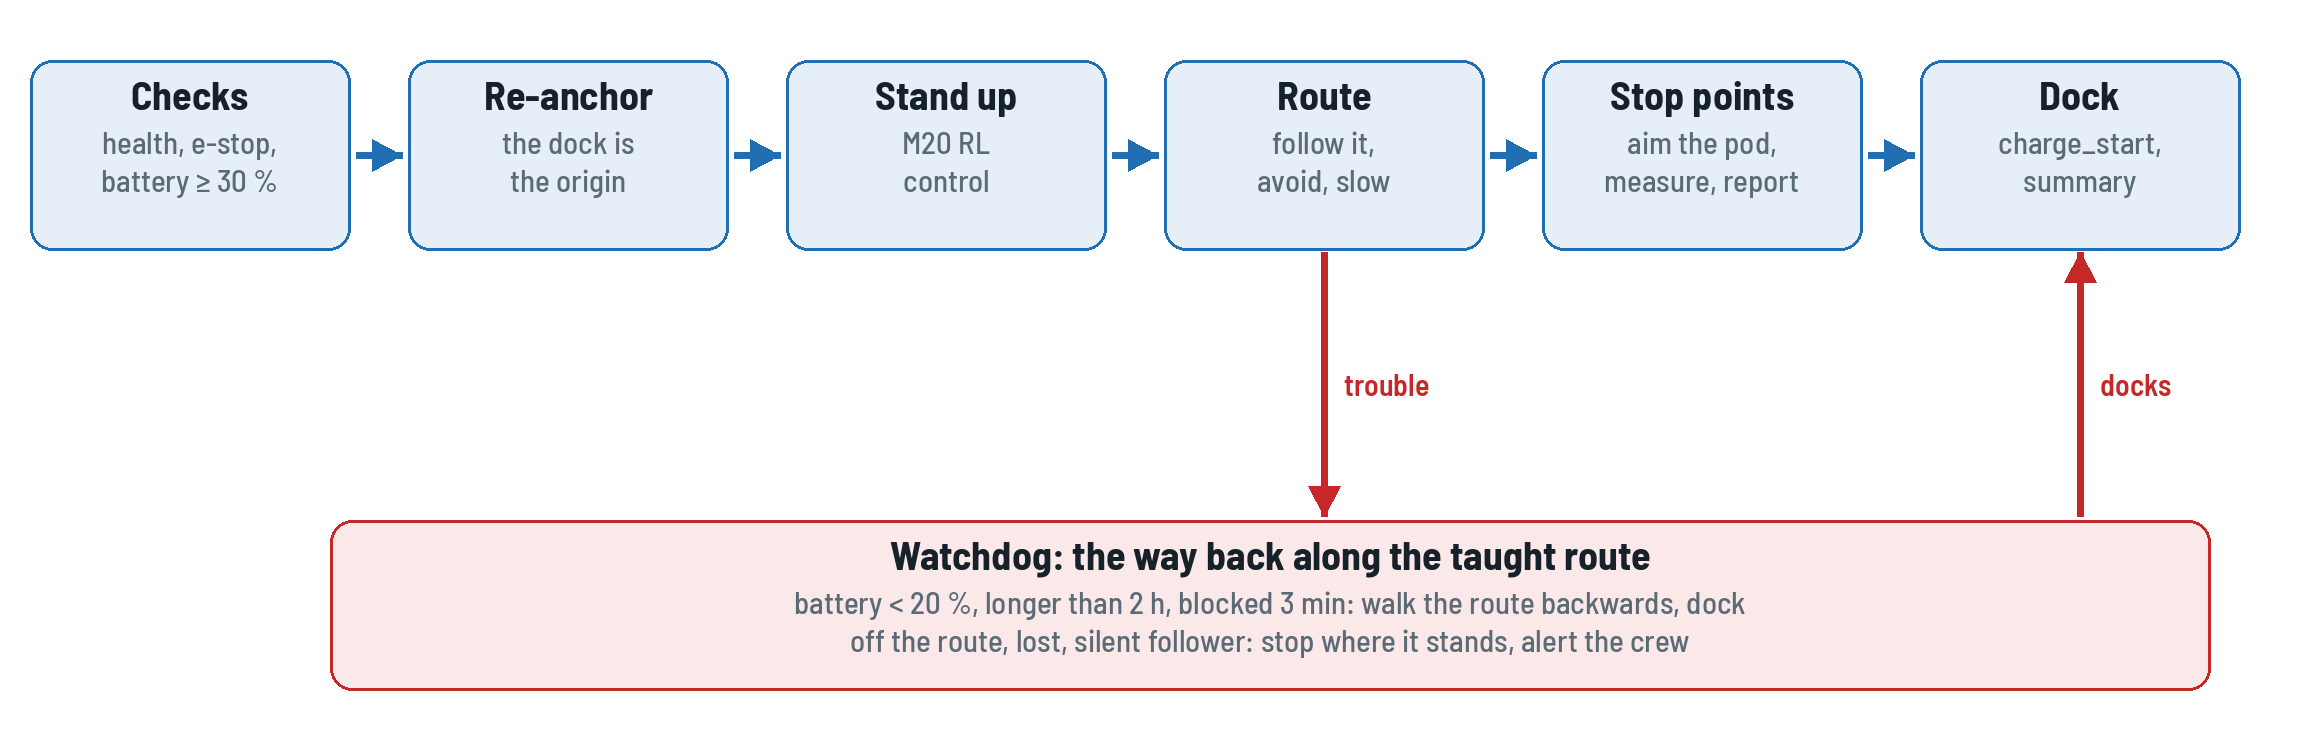
A watchdog guards every patrol: a low battery, an overlong patrol or a robot blocked for too long sends it back to the dock along the taught route; off the route, lost or without its follower it stops and calls the crew. It never overrules an operator's pause, the e-stop or the M20 remote.
Architecture
                 ┌────────────────────────────────────────────────────────────────────┐
 HotDog          │ patrol_node: dock -> route -> dock, schedule, watchdog, way back   │
                 │ inspection_node: overheat (UniPod MT11), partial discharge (HZ-FA) │
                 │ report_node: pages on :8088 · alert_node: Telegram, webhook        │
                 ├────────────────────────────────────────────────────────────────────┤
 Dharma          │ path follower (stop points -> inspection hook) · avoidance         │
                 │ sites and taught routes · localization (dock = map origin)         │
                 │ sector scans · control mux (only cmd_vel, e-stop, field) · health  │
                 ├────────────────────────────────────────────────────────────────────┤
 robot           │ m20_driver: odometry camera_init -> body, IMU, battery, cmd_vel    │
                 │ cloud_merger_node: front + rear Airy -> /lidar/points              │
                 │ unipod_driver: gimbal, zoom, streams, temperatures                 │
└────────────────────────────────────────────────────────────────────┘- Odometry only. The M20's own dead reckoning is the odometry, nothing is mapped; the dock is the origin of the map frame, re-anchored before every patrol.
- Motion has one way out. The control mux is the only publisher of
/m20/cmd_vel; the protective field on the 360° scan of both Airy, the health speed limit and the latched e-stop apply to every source. m20_driver stops on its own without fresh commands. - Inspection never holds the patrol. The follower calls
inspection/inspectat each stop point; a stop without an inspection point, a missing pod or camera answers and the robot moves on; everything found is in the reports.
Packages
| Package | Role |
|---|---|
hotdog | the robot: profile, M20 driver settings, stack config, robot.launch.py, sim.launch.py |
hotdog_base | both RoboSense Airy as one leveled cloud in base_link, the shared launch helpers |
hotdog_inspection | inspection at the stop points: overheat, partial discharge, reports, teaching |
hotdog_patrol | patrols from the dock, on demand or on a schedule, the watchdog, the way back to the dock |
hotdog_reports | HTML patrol reports with the last round of every finding, retention, the server on 8088 |
hotdog_alerts | findings, patrols and health ERROR to Telegram and a webhook, spooled while offline |
hotdog_interfaces | findings, inspection reports and status, AddTarget |
The stack (dharma_*) is pinned in dharma.repos, the M20, pod and Airy drivers in external.repos.
Which guide
| You | Read |
|---|---|
| operate the robot on a shift | the User Manual, then Operations as a quick reference |
| bring up a new robot or substation | Commissioning, then the Technician Guide |
| hand a robot over to a substation | the Site Acceptance Test |
| change the code | the packages, Contributing and the quick start below |
Every guide is also an A5 PDF, sized to read on a phone during a shift: the PDF menu above.
Develop
git clone git@github.com:DarmawanRobotics/HotDog.git && cd HotDog
scripts/dev.sh up                     # dev container (ROS 2 Foxy, VNC): imports the repos
scripts/dev.sh build && scripts/dev.sh test
scripts/dev.sh shell
ros2 launch hotdog sim.launch.py rviz:=true          # the stack on dharma_sim, no robot
This site is built from docs/ with VitePress (cd docs && npm ci && npm run dev); the guides are the same Markdown as the PDFs (python3 docs/pdf/build.py).